> For the complete documentation index, see [llms.txt](https://renownedgames.gitbook.io/ai-tree/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://renownedgames.gitbook.io/ai-tree/nodes/tasks/transform/get-rotation.md).
# Get Rotation
Node description and basic instructions
### Description
Get rotation of transform.
**To create it**, right-click in the editor and select Create Node/Tasks/Transform/Get Rotation
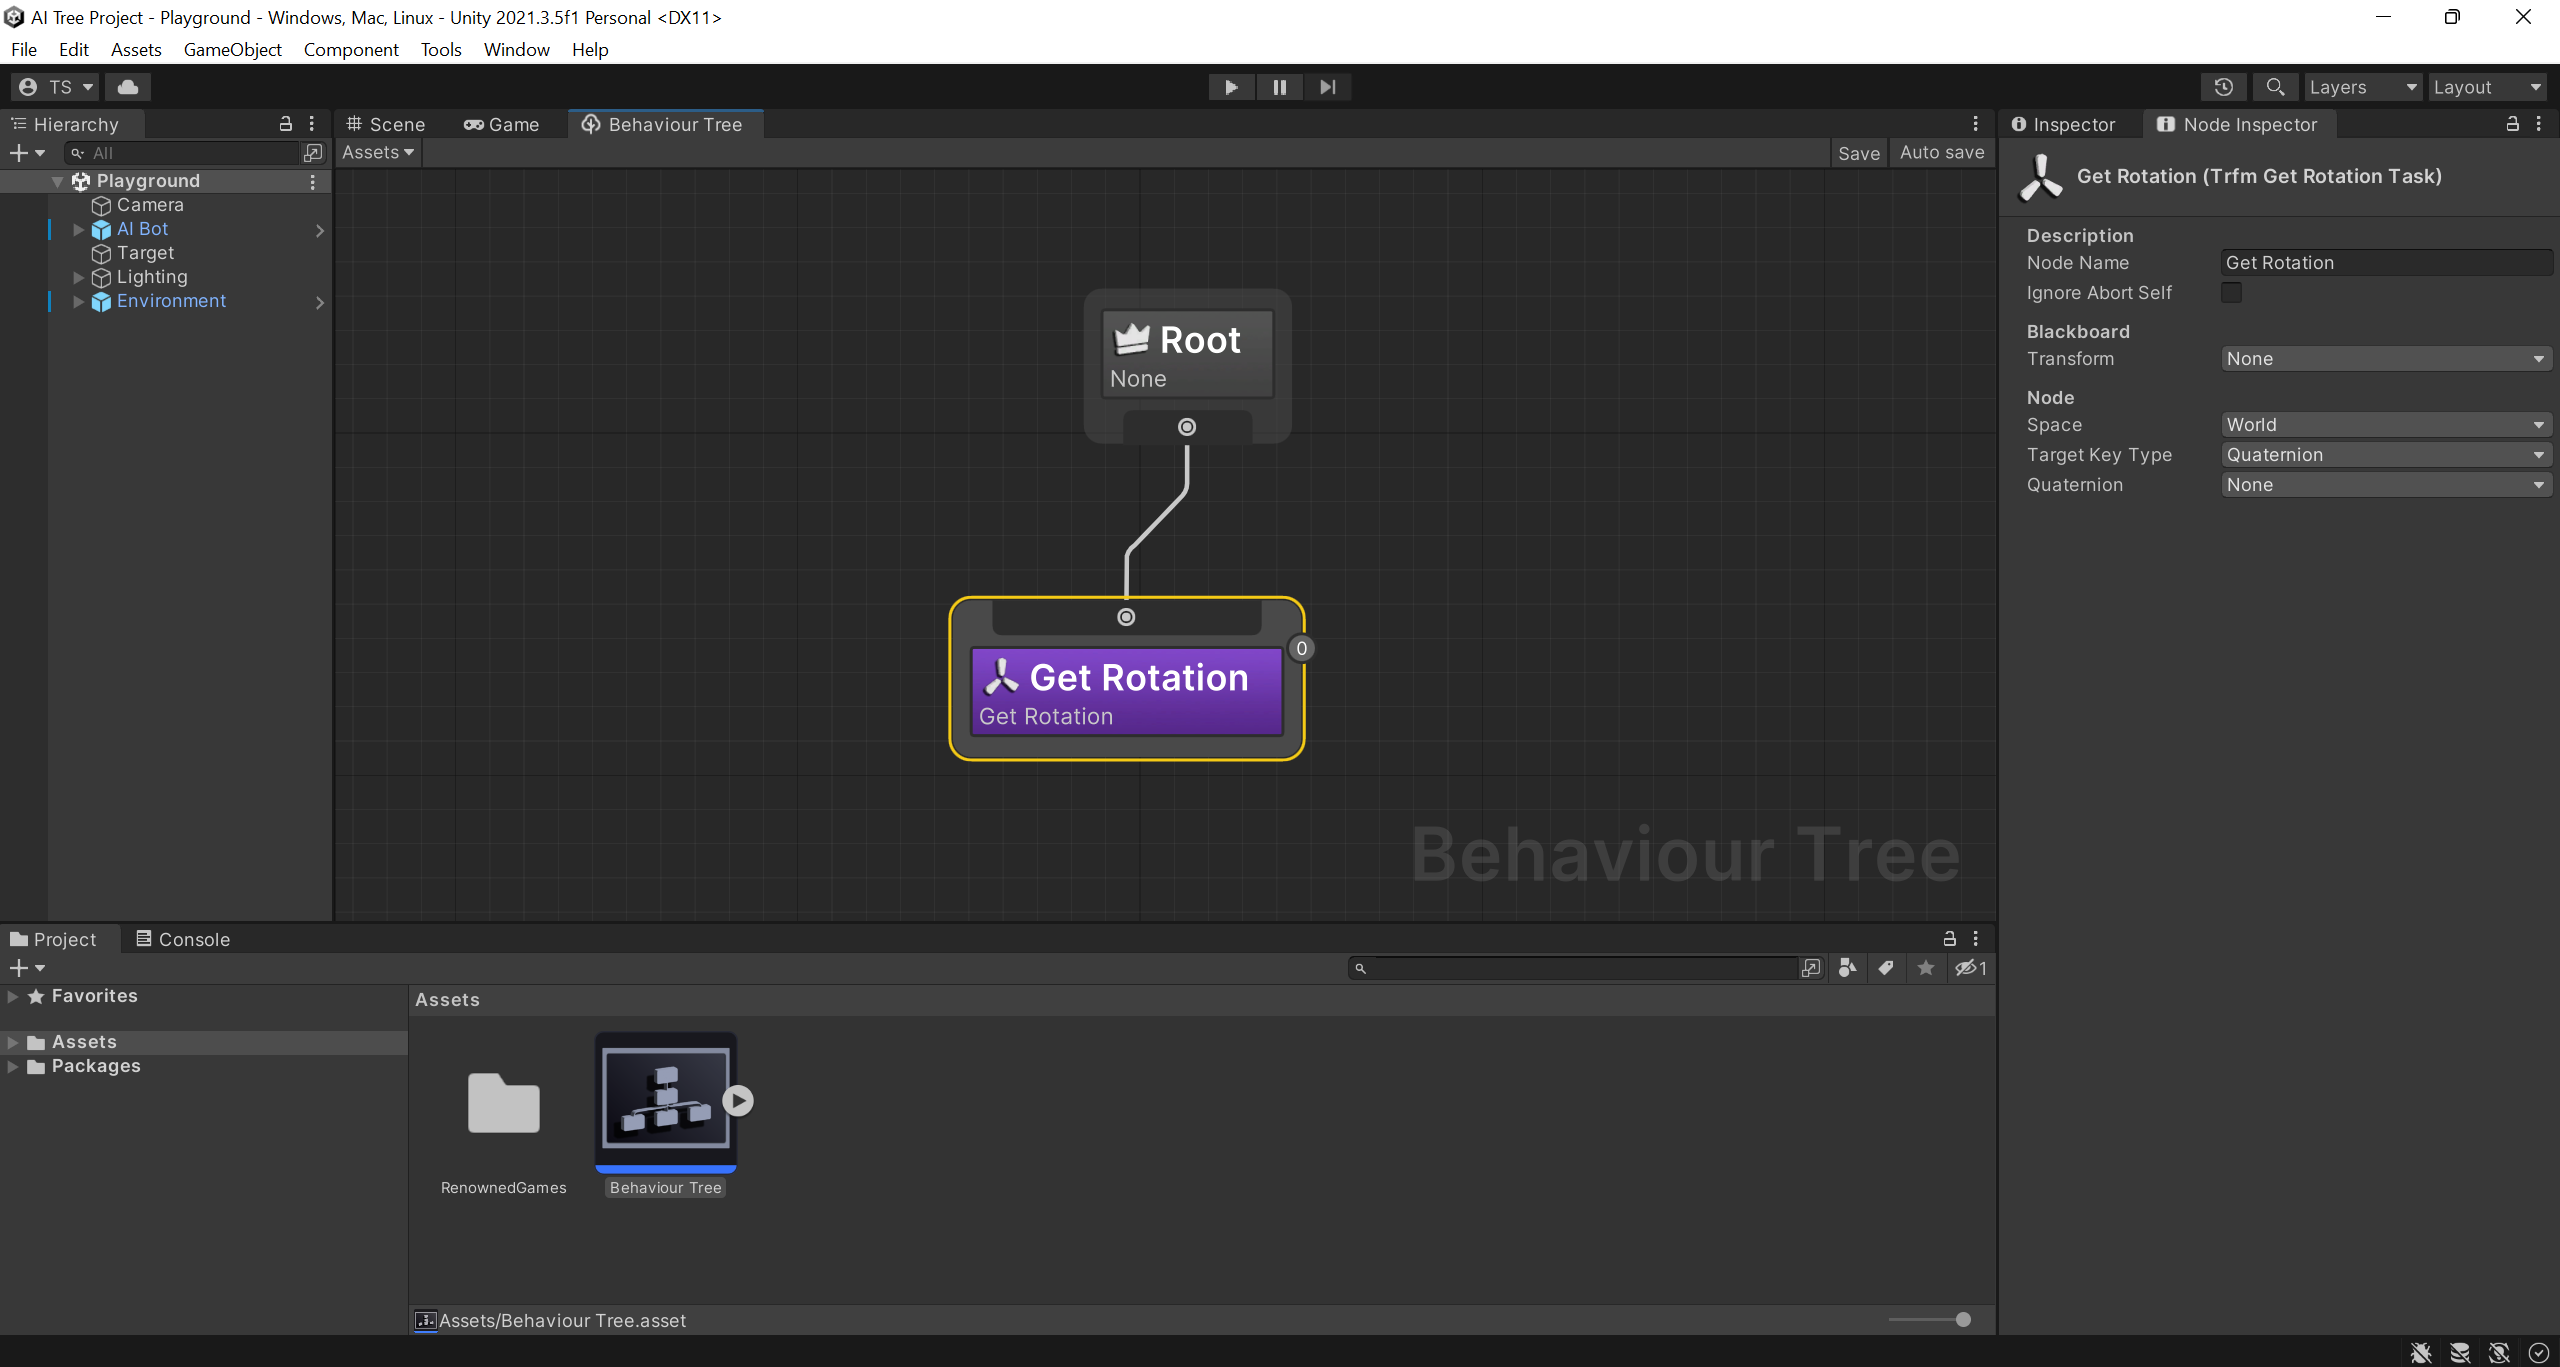
This task node has a number of fields, that are highlighted in picture below.
### Fields
| Name | Description |
| ----------------------- | ---------------------------------------------------------------------------------------------------------------- |
| Node Name | Name of node. |
| Ignore About Self | Whether node ignores abort self or not. |
| Transform | Transform reference to start from. |
| Space | World or local space. |
| Target Key Type | How to store position? In Quaternion, EulerAngles (Vector3) or seperate x,y,z EulerAngles (Vector3) key values. |
| Quaternion/Vector/X,Y,Z | Key to store values. |